
二维分段与无限线相交算法
二维分段与无限线相交算法
提问于 2022-01-18 12:09:34
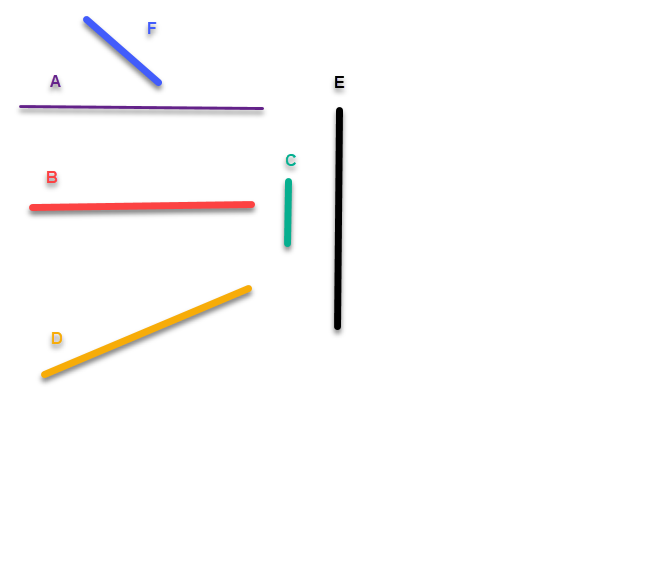
我试图构建逻辑,通过只扩展中的一个,来检测可能与相交的时间。
在这里,我们有段。A,B,C,D,E,F,每段都有“两点”。
我们总是需要比较两个部分。一个可以扩展,另一个可以在当前状态下保持不变。
如果我们将A与C进行比较,就会得到"false“。
如果我们将B与C进行比较,我们就会得到"true“
如果我们将D与C进行比较,我们就会得到"false“,因为无论你能扩展D多长时间,它仍然不会与C相交
如果我们将E与C进行比较,我们将得到"false“,因为无论你能扩展E多长时间,它仍然不会与C相交
如果我们将F与C进行比较,我们将得到"true“
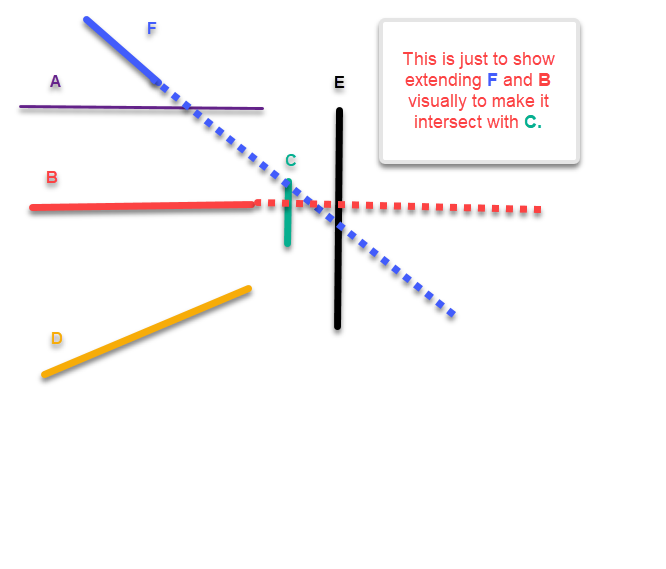
下面的图片只是一个扩展的例子。
回答 1
Stack Overflow用户
回答已采纳
发布于 2022-01-18 15:09:21
我想你是在找这个
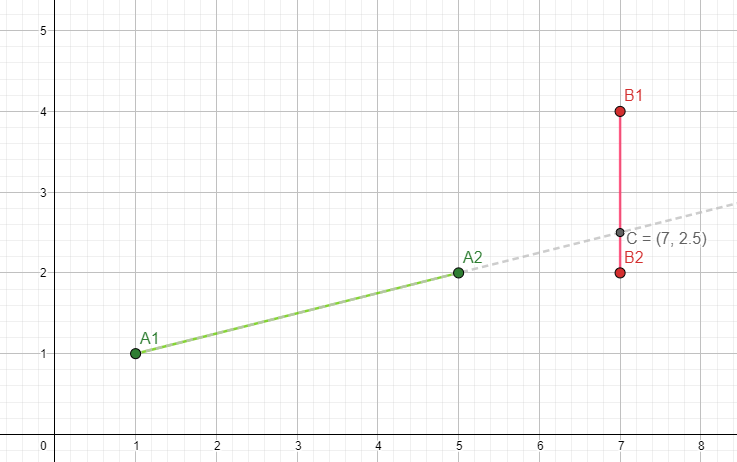
    static void Main(string[] args)
    {
        var A = new Segment(Point.Cartesian(1, 1), Point.Cartesian(5, 2));
        var B = new Segment(Point.Cartesian(7, 2), Point.Cartesian(7, 4));

        if (A.AsRay.Intersect(B, out var point))
        {
            Console.WriteLine(point);
            // (7, 2.5)
        }
    }
为了使它以对我来说有意义的方式发生,我必须实现以下类
Vector.cs
public readonly struct Vector
{
    public Vector(double uX, double uY) : this()
    {
        UX=uX;
        UY=uY;
    }
    public static readonly Vector Zero = new Vector(0, 0);
    public static readonly Vector UnitX = new Vector(1, 0);
    public static readonly Vector UnitY = new Vector(0, 1);

    public static Vector Cartesian(double ux, double uy)
        => new Vector(ux, uy);

    public static Vector Polar(double r, double θ)
        => new Vector(r*Math.Cos(θ), r*Math.Sin(θ));

    public double UX { get; }
    public double UY { get; }

    public double SumSquares { get => UX*UX+UY*UY; }
    public double Magnitude { get => Math.Sqrt(SumSquares); }

    public Vector Unit()
    {
        double m2 = UX*UX+UY*UY;
        if (m2>0)
        {
            return this/Math.Sqrt(m2);
        }
        return this;
    }
}
Point.cs
public readonly struct Point
{
    /// <summary>
    /// Initializes a <see cref="Point"/> from <code>(x,y)</code> coordinates.
    /// </summary>
    /// <param name="x">The x.</param>
    /// <param name="y">The y.</param>
    public Point(double x, double y) : this()
    {
        X=x;
        Y=y;
    }
    public static readonly Point Origin = new Point(0, 0);

    public static Point Cartesian(double ux, double uy)
        => new Point(ux, uy);

    public static Point Polar(double r, double θ)
        => new Point(r*Math.Cos(θ), r*Math.Sin(θ));

    public double X { get; }
    public double Y { get; }

    /// <summary>
    /// Find the point where two lines intersect, if it exists.
    /// </summary>
    /// <param name="g">The first line.</param>
    /// <param name="h">The second line.</param>
    public static bool Intersect(Line g, Line h, out Point point)
    {
        double d = g.A*h.B - h.A * g.B;
        if (d!=0)
        {
            point = new Point(
                (g.B*h.C - h.B*g.C)/d,
                (h.A*g.C - g.A*h.C)/d);
            return true;
        }
        point = Point.Origin;
        return false;
    }

    public double DistanceTo(Point target)
        => Math.Sqrt((X-target.X)*(X-target.X) + (Y-target.Y)*(Y-target.Y));
}
Line.cs
public readonly struct Line
{
    /// <summary>
    /// Initializes a <see cref="Line"/> from the <code>(a,b,c)</code> coordinates.
    /// Note that the equation of the line is <code>a*x+b*y+c=0</code>
    /// </summary>
    /// <param name="a">The a coefficient.</param>
    /// <param name="b">The b coefficient.</param>
    /// <param name="c">The c constant.</param>
    public Line(double a, double b, double c) : this()
    {
        A=a;
        B=b;
        C=c;
    }
    public static readonly Line AlongX = new Line(0, 1, 0);
    public static readonly Line AlongY = new Line(1, 0, 0);
    public static readonly Line Infinity = new Line(0, 0, 1);
    /// <summary>
    /// Find the line that joins two points
    /// </summary>
    /// <param name="p">The first point.</param>
    /// <param name="q">The second point.</param>
    /// <returns></returns>
    public static bool TryJoin(Point p, Point q, out Line line)
    {
        if (!p.Equals(q))
        {
            line = new Line(p.Y-q.Y,q.X-p.X, p.X * q.Y - p.Y * q.X);
            return true;
        }
        line = Line.Infinity;
        return false;
    }

    public double A { get; }
    public double B { get; }
    public double C { get; }

    public Vector Direction { get => Vector.Cartesian(-B, A).Unit(); }
    public Vector Normal { get => Vector.Cartesian(-A*C, -B*C).Unit(); }

    public Line Normalized()
    {
        double m = Math.Sqrt(A*A+B*B);
        if (m>0)
        {
            return new Line(A/m, B/m, C/m);
        }
        return this;
    }

    /// <summary>
    /// The line origin is the point on the line closest to the origin.
    /// </summary>
    public Point Origin => Project(Point.Origin);
    /// <summary>
    /// Find a point on the line a specified distance from the
    /// line origin.
    /// </summary>
    /// <param name="distance">The distance.</param>
    public Point PointAlong(double distance)
    {
        double m2 = A*A+B*B;
        double m = Math.Sqrt(m2);

        return new Point(
            -(B*distance*m+A*C)/m2,
            (A*distance*m-B*C)/m2);
    }
    /// <summary>
    /// Distances the along.
    /// </summary>
    /// <param name="point">The point.</param>
    public double DistanceAlong(Point point)
        => (A*point.Y-B*point.X)/Math.Sqrt(A*A+B*B);

    /// <summary>
    /// Find point on line closest to target point
    /// </summary>
    /// <param name="target">The target point.</param>
    /// <returns></returns>
    public Point Project(Point target)
    {
        double m2 = A*A+B*B;
        return new Point(
            (B*(B*target.X-A*target.Y)-A*C)/m2,
            (A*(A*target.Y-B*target.X)-B*C)/m2);
    }
    /// <summary>
    /// Find perpendicular distance to a point
    /// </summary>
    /// <param name="point">The point.</param>
    /// <param name="signed">signed distance flag.</param>
    /// <returns>The distance to a point. The value might be negative
    /// if point is "below" the line and the signed flag is turned on.</returns>
    public double DistanceTo(Point point, bool signed = false)
    {
        var d = A*point.X+B*point.Y+C;
        var m = Math.Sqrt( A*A+B*B );

        return signed ? d/m : Math.Abs(d)/m;
    }

    /// <summary>
    /// Determines whether this line contains a point.
    /// </summary>
    /// <param name="point">The point.</param>
    /// <param name="tolerance">The length tolerance to use.</param>
    public bool Contains(Point point, double tolerance = 1e-11)
    {
        return DistanceTo(point, false)<=tolerance;
    }
}
Segment.cs
public readonly struct Segment
{
    public Segment(Point start, Point end) : this()
    {
        Start=start;
        End=end;
    }
    public Segment(Ray ray, double distance)
        : this(ray.Start, ray.PointAlong(distance))
    { }

    public Point Start { get; }
    public Point End { get; }

    /// <summary>
    /// Gets the infinite line through the segment.
    /// </summary>
    public Line InfiniteLine
    {
        get
        {
            if (Line.TryJoin(Start, End, out var line))
            {
                return line;
            }
            return line;
        }
    }
    public Ray AsRay => new Ray(Start, End);

    public bool Contains(Point point, double tolerance = 1e-11)
    {
        var L = InfiniteLine;
        if (L.Contains(point, tolerance))
        {
            point = L.Project(point);

            var d = L.DistanceAlong(point);
            var dA = L.DistanceAlong(Start);
            var dB = L.DistanceAlong(End);

            var t = (d-dA)/(dB-dA);

            return t>=0 || t<=1;
        }
        return false;
    }
}
Ray.cs
public readonly struct Ray
{
    public Ray(Point start, Vector direction) : this()
    {
        Start=start;
        Direction=direction.Unit();
    }

    public Ray(Point start, Point end) : this(start, end-start) { }

    public Point Start { get; }
    public Vector Direction { get; }

    public Point PointAlong(double distance)
        => Start + distance * Direction;

    public Ray Flip => new Ray(Start, -Direction);

    public Line InfiniteLine
    {
        get
        {
            double d = Start.X * Direction.UY - Start.Y * Direction.UX;
            return new Line(-Direction.UY, Direction.UX, d);
        }
    }
    /// <summary>
    /// Determines whether this ray contains a point.
    /// </summary>
    /// <param name="target">The target point.</param>
    /// <param name="tolerance">The distance tolerance.</param>
    public bool Contains(Point target, double tolerance = 1e-11)
    {
        var L = InfiniteLine;
        if (L.Contains(target, tolerance))
        {
            double d = L.DistanceAlong(target);
            double dA = L.DistanceAlong(Start);
            return d<=dA;
        }
        return false;
    }

    /// <summary>
    /// Determines whether this ray intersects a line segment, and return the
    /// intersection point.
    /// </summary>
    /// <param name="target">The target segment.</param>
    /// <param name="tolerance">The distance tolerance.</param>
    public bool Intersect(Segment target, out Point point, double tolerance = 1e-11)
    {
        if (Point.Intersect(InfiniteLine, target.InfiniteLine, out point))
        {
            return Contains(point, tolerance)
                && target.Contains(point, tolerance);
        }
        return false;
    }
}
一些值得注意的能力是:
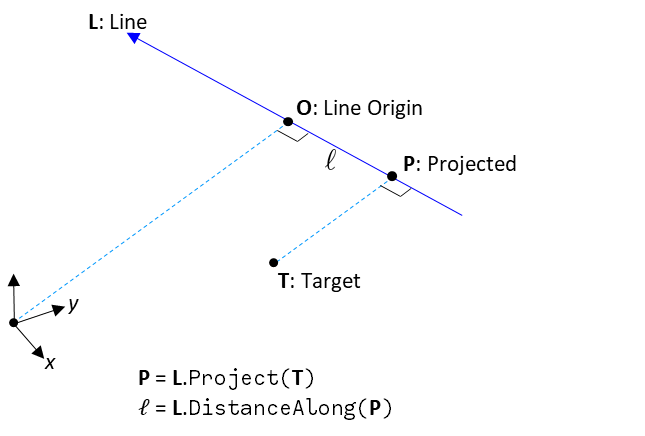
Point.Intersect(Line g, Line h, out Point point)找到两条无限lines.Line.TryJoin(Point p, Point q, out Line line)查找线的交点--沿着一条从原点(最近于坐标原点的点)到目标point.Line.Project(Point target)的直线连接两条points.Line.DistanceAlong(Point point)距离,查找与目标point.Line.Contains(Point point)最近的点,检查是否有一个点位于直线上(在tolerance).Ray.Contains(Point point)检查内,如果一个点位于射线上,并且位于射线所定义的方向。H 225
code>
Ray.Intersect(Segment target, out Point point)检查射线是否与段相交并返回点
以下是Line.Project()和Line.DistanceTo()的三维表示
页面原文内容由Stack Overflow提供。腾讯云小微IT领域专用引擎提供翻译支持
原文链接:
https://stackoverflow.com/questions/70755385
复制相关文章
相似问题
腾讯云开发者

Copyright © 2013 - 2026 Tencent Cloud. All Rights Reserved. 腾讯云 版权所有
深圳市腾讯计算机系统有限公司 ICP备案/许可证号:粤B2-20090059  粤公网安备44030502008569号
腾讯云计算(北京)有限责任公司 京ICP证150476号 | 京ICP备11018762号